
About
I am a PhD student at the School of Computer Science, Rutgers University, advised by Prof. Jingjin Yu.
Prior to this, I obtained a BSc degree with Honor Degree (top 5%) in Artificial Intelligence from the University of Science and Technology of China (USTC).
My research focuses on developing more capable and trustworthy robot brains that allow robots to work efficiently and reliably in household environments.
The kitchen, as a compact yet highly representative domestic space, serves as an ideal testbed for this research.
I organize kitchen-related tasks into three main categories:
- Ingredient Preparation: Preparing raw ingredients for cooking.
- Cooking: Autonomously turning prepared ingredients into delicious meals.
- Post-Meal Tidying: Restoring the kitchen to a clean state for the next round of cooking.
We have shipped OrganizeIt as part of our work on post-meal tidying, and are also making progress on the other two categories.
Selected Publications
View All →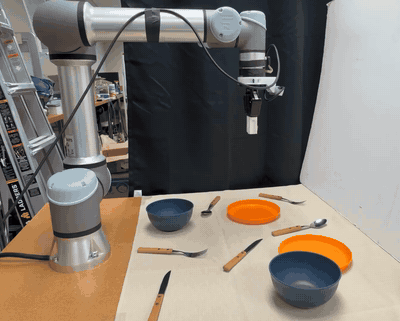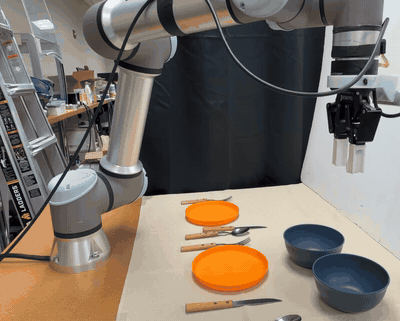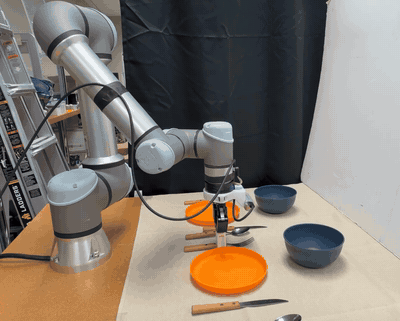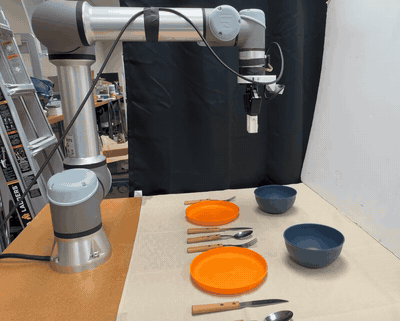
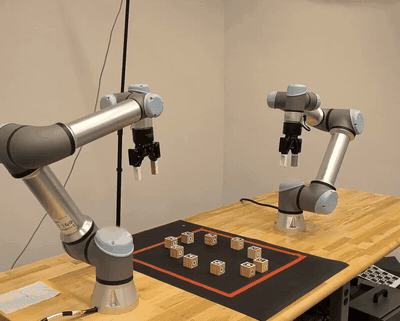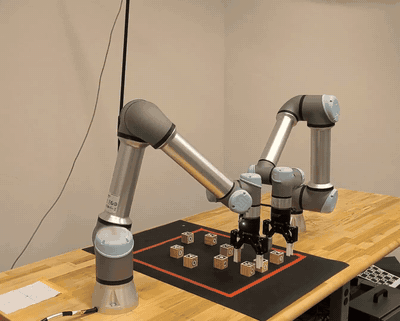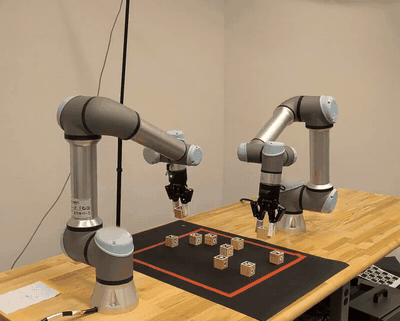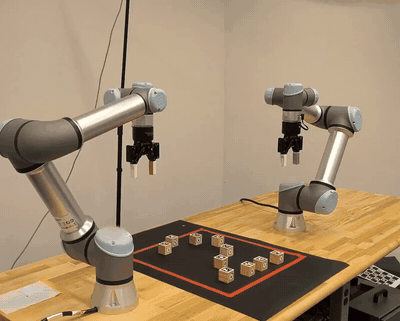
OrganizeIt: Compiling Generated Images into Tidy Tabletop Arrangements
Junshan Huang, Xiyu Ke, Jintong Li, Litao Liu, Duo Zhang, Jingjin Yu
Under Review
Achieve zero-shot, CAD-free, general tabletop organization with future image guidance and relational structure guarantees.
High-Performance Dual-Arm Task and Motion Planning for Tabletop Rearrangement
Duo Zhang, Junshan Huang, Jingjin Yu
Proceedings of the IEEE International Conference on Robotics and Automation (ICRA)
We propose SDAR, a dual-arm rearrangement planner that efficiently solves complex, entangled object manipulation tasks through synchronous task and motion planning.

VLA-OS: Structuring and Dissecting Planning Representations and Paradigms in Vision-Language-Action Models
Chongkai Gao, Zixuan Liu, Zhenghao Chi, Junshan Huang, Xin Fei, Yiwen Hou, Yuxuan Zhang, Yudi Lin, Zhirui Fang, Lin Shao
Advances in Neural Information Processing Systems (NeurIPS)
Unified benchmarking reveals visually grounded hierarchical planning excels in VLAs.
News
🎉 Our paper SDAR was accepted by ICRA 2026!
🎉 Our paper VLS-OS accepted by NeurIPS 2025!
Starting my PhD at the Rutgers University~
🎓 Graduated from USTC with a honor degree! (Top 5%)
Awarded the AI Talent Program Scholarship from USTC.
Awarded the Shenzhen Stock Exchange Scholarship.
We win the 1st place in the ACM REACT 2023 Multimodal Challenge!